
news
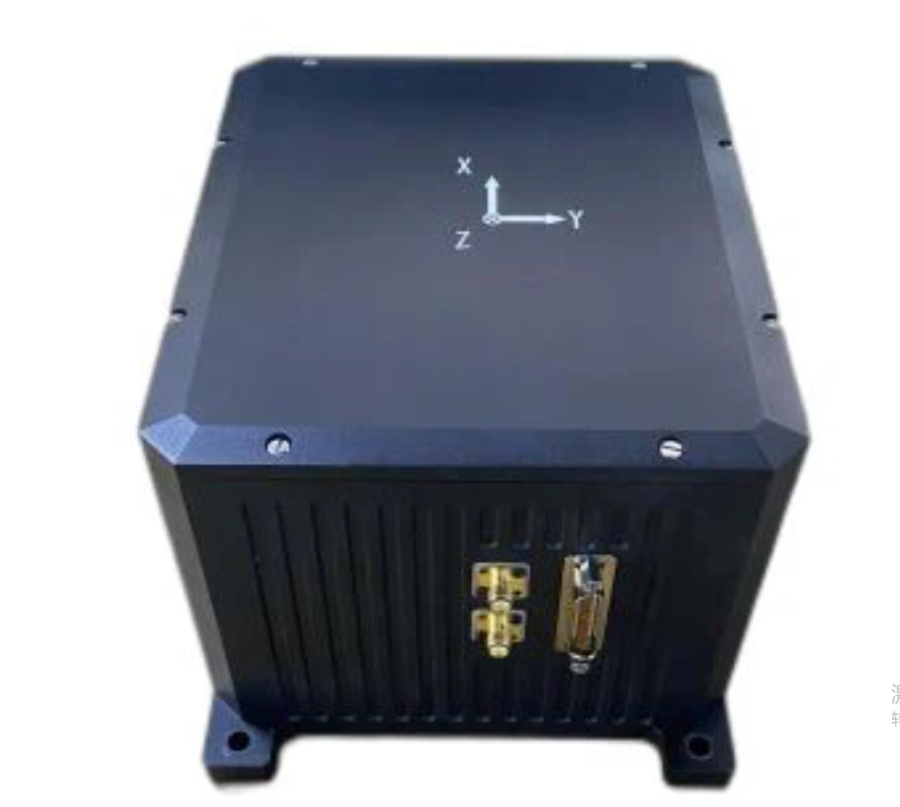
Why Buy Inertial Navigation System?
Why Buy Inertial Navigation System?
Whether you’re driving a car, riding a train or flying a commercial aircraft or drone, chances are that you’re using an inertial navigation system (INS).buy inertial navigation system One of the most significant technological advancements of our time, INS technology is accurate, reliable and now affordable for a wide range of emerging applications and markets. Inertial navigation systems are an essential part of the modern world. But what exactly is an inertial navigation system, how does it work, and why do we need it?
The heart of any INS is the inertial measurement unit (IMU), which senses accelerations and rotations.buy inertial navigation system The IMU outputs raw motion data that is then processed by the onboard computer of an INS. The IMU sensor fusion software combines the acceleration data from the IMU with the GNSS position information to determine the object’s precise location and movement in three-dimensional space.
Accelerometers measure changes in velocity, or distance travelled, along three perpendicular axes – x, y, and z. These measurements are integrated over time to calculate the current velocity of the device in its own frame of reference – which is its inertial system. The IMU also includes a set of gyroscopes that detect changes in rotational position, or pitch, roll, and yaw. By comparing the angular displacement of the IMU to its initial orientation in its inertial system, the software can identify the current rotational position and angle of attack.
For more accuracy, the IMU includes a magnetometer that measures the direction of Earth’s magnetic field at its location. This information is compared to a map of the world’s magnetic field strengths at each point, a three-dimensional coordinate system called the World Magnetic Model (WMM). This information is used by the sensor fusion software to determine an object’s absolute heading in its own frame of reference, and then compared to the WMM to calculate a new, more accurate direction.
The combined IMU and GNSS position data is then fed into a Kalman filter, which performs a series of iterations to estimate the current position. The filter uses a mathematical technique that combines short-term sensor noise correction and long-term integration drift. In this way, the INS can achieve high-accuracy positions over minutes and hours despite the accumulation of small errors in acceleration and angular velocity measurements. This is the fundamental reason why INS has become such an integral part of everyday life and critical to emerging industries like autonomous vehicles, drones, and surveying.
1users like this.
- Home
-
All Products
Your cart is currently empty.