
news
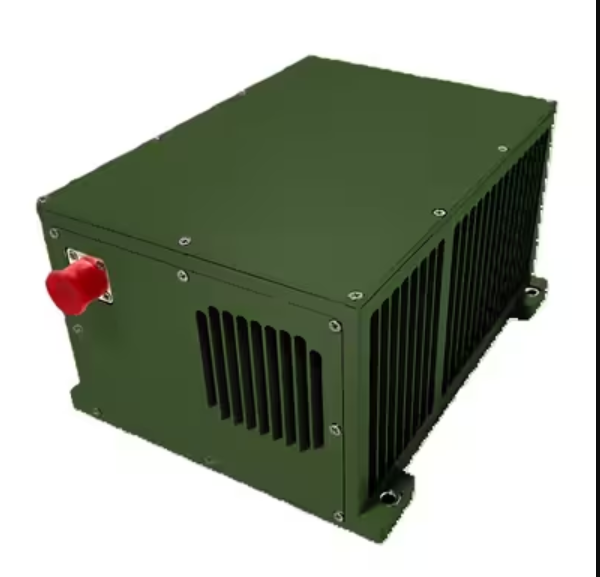
How Do Inertial Navigation Systems Work?
How Do Inertial Navigation Systems Work?
Inertial navigation systems (INS) are a vital component in a wide range of applications, from submarines to spacecraft and autonomous vehicles.gps ins They provide a rich set of measurements including position, velocity and orientation – all without the need for external signals from satellites or cell phone towers. But how do they work, and what challenges do they face? This article explores these questions and more.
At the core of every INS is an inertial measurement unit, or IMU.gps ins These motion sensors typically consist of three gyroscopes and three accelerometers, but some IMUs also contain magnetometers. Together, these sensors report changes in an object's movement over time to a computer system that translates the IMU output into navigation information.
There are several different integration architectures that can be used to couple the IMU and GNSS sensor measurements, each with advantages and disadvantages.gps ins These architectures are characterized as loosely-coupled, tightly-coupled, and ultra-tightly coupled.
Loosely-coupled INS/GNSS systems use a Kalman filter to combine the GNSS and IMU outputs.gps ins This approach uses raw GNSS pseudorange and Doppler data along with the integrated position, velocity and orientation output from the INS to produce a navigation solution. This solution is then fed back into the INS to reduce bias and improve accuracy.
Tightly-coupled INS/GNSS architectures take a similar approach to the loosely-coupled solution but do not require the full navigation solution computed by the INS.gps ins In this case, the GNSS and INS outputs are merged into a single system through an extended Kalman filter. This is a less computationally intensive approach that can be more robust in the presence of signal outages or other environmental challenges.
Ultra-tightly-coupled INS/GNSS navigation systems use an algorithm called a continuous state estimation, or CSE, to combine the GNSS and IMU inputs.gps ins This algorithm is based on the nonlinear least squares problem and is solved using matrix algebra techniques like the Cholesky decomposition or the unscented transformation. This technique is fast, accurate, and scalable to large system dimensions.
As navigation technology has evolved, so have the capabilities of INS.gps ins Today, INS can be tightly-coupled to a GNSS system or used with complementary sensors such as LiDAR scanners and stereo cameras. Custom output formats can be used to enable these integrations, allowing users to customize their INS for a specific application.
As the need for precise positioning, reliable navigation and timing increases, so too does the demand for INS and IMU technologies. Whether it's in submarines diving to the ocean floor or autonomous machines harvesting minerals from mine sites, a modern INS can play an important role in ensuring safe and efficient operation.
Tags:ins system | ultra low drift ins
1users like this.
- Home
-
All Products
Your cart is currently empty.