
news
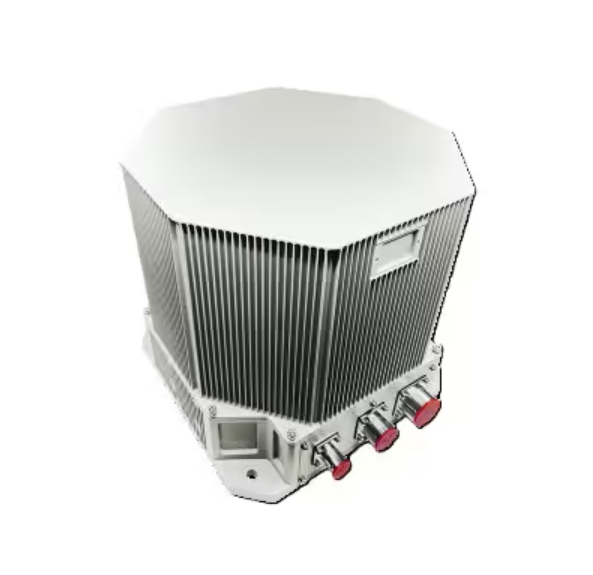
GNSS-INS Integration Explained
GNSS-INS Integration Explained
GNSS-INS integration is used in a wide range of applications from autonomous vehicles to industrial machinery.gnss ins In each case the integrated system provides absolute position and attitude information to the platform that isn’t available from an IMU alone.gnss ins This is critical for enabling many of these systems to work in GNSS-denied environments such as when satellite signals are blocked by canyon walls or bridges, or when radio frequency interference degrades positioning accuracy.
A GNSS-INS system combines the outputs of the two navigation technologies to deliver a powerful, continuous, high-accuracy navigation solution that is more reliable than any single technology on its own.gnss ins For example, a GNSS-INS system is ideal for hydrographic surveying where vessel roll and pitch can obstruct satellite signals. Or when a ship is operating in busy ports where radio frequency interference can degrade the quality of a GNSS fix. And when a multibeam echosounder is working to capture precise depth data below the waterline, a robust GNSS-INS provides consistent positioning to enable the acoustic system to operate reliably.
There are several different ways to combine GNSS and INS, often referred to as loosely-coupled, tightly-coupled or ultra-tightly-coupled systems.gnss ins In the simplest form, a GNSS receiver uses its measurements of position and velocity to help estimate the errors in an INS solution using an extended Kalman filter. This enables the combined system to achieve metre- to centimetre-level accuracy even when IMUs are exposed to large errors such as multi-path, multi-fingered signal delays.
More advanced GNSS-INS solutions use raw GNSS measurements to help guide the tracking loops of a GNSS receiver.gnss ins This is known as a tight coupling and allows the GNSS-INS to provide fast, high-rate feedback to maintain a tracking lock on the carrier signals transmitted by the GNSS satellites. Tight coupling enables the combined system to rapidly reacquire lost satellites and reject bad signals, resulting in a more robust and accurate navigation solution.
Lastly, there are GNSS-INS solutions that use an approach called sensor fusion to fuse inputs from multiple sensors including the GNSS receiver.gnss ins This is a more sophisticated way of improving overall performance as the output of the GNSS-INS system is not just a position coordinate but also a full navigation state, consisting of position, velocity and full three-axis attitude (roll, pitch, heading) updated at the IMU’s high rate. This is particularly valuable when one or more of the GNSS signals are jammed or subjected to spoofing.
Spoofing attacks occur when someone intentionally attempts to manipulate the signals sent by a GNSS satellite or network, in order to gain control of the device that is receiving the spoofed signals.gnss ins Septentrio GNSS-INS systems are designed with anti-spoofing security in mind, providing resilience to these kinds of threats through the use of a GNSS receiver that has a built-in spoofing detection and warning system. This helps protect against the most common forms of spoofing, but more sophisticated attacks may require additional protection mechanisms.
1users like this.
- Home
-
All Products
Your cart is currently empty.