
news
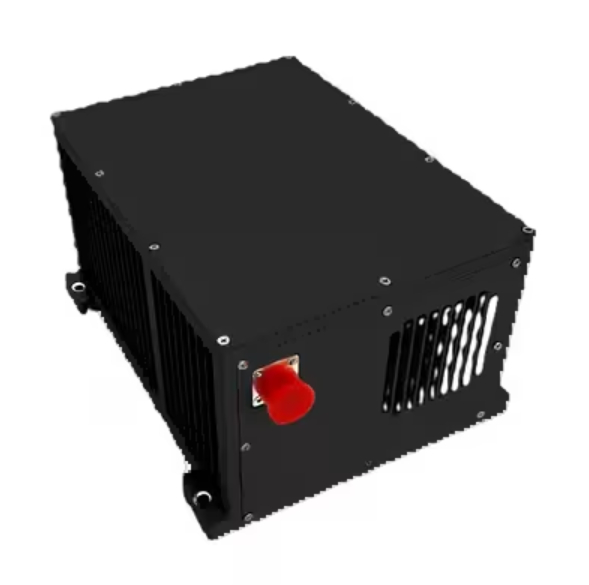
GNSS-INS Integration
GNSS-INS Integration
GNSS-INS integration is a key navigation technology that integrates global positioning satellite (GPS) data with inertial measurement units (IMU).gnss ins integration By combining GPS and IMU measurements, gnss ins integration offers the best combination of accuracy and reliability for a wide range of maritime and aviation applications. When the GNSS signal is lost or jammed, the IMU takes over seamlessly and continues providing navigation guidance. In addition, the integrated navigation system can maintain a high output rate for continuous tracking of moving objects.
Currently, there are several different approaches for integrating GNSS-INS data.gnss ins integration The most widely used approach is the loosely-coupled GNSS/INS integration architecture, which uses a Kalman filter to combine the INS and GNSS navigation solutions. During integration, the EKF predicts the combined system’s position, velocity, and attitude, using the INS measurements as input. The predicted state is then compared with the actual GNSS measurements, which are fed into the INS, to calculate the residual term. This residual value is a good indicator of how well the combined system is performing. Smaller residuals typically indicate that the GNSS and INS are closer to their optimal estimation.
Another popular GNSS-INS integration method is the tightly coupled (TC) architecture.gnss ins integration During this integration, the INS helps drive the tracking loops of the GNSS receiver, which are responsible for tracking the reflected carrier signals from multiple paths. This allows the GNSS receiver to use a narrower tracking bandwidth, which improves positioning performance. Additionally, the INS can help provide high-rate feedback to the GNSS tracking loops, which improves stability by reducing multi-path effects.
In a TC GNSS/INS system, the INS is also responsible for subtraction of the system’s acceleration due to motion and the pseudo-acceleration caused by gravity.gnss ins integration These acceleration measurements are then integrated twice to determine the system’s velocity and position. Therefore, it is essential that the INS provide an accurate attitude estimate. If the INS fails to maintain an accurate attitude estimate, then errors in the calculated velocity and position will be introduced.
A new GNSS-INS integration technique that is gaining popularity is the factor graph optimization (FGO) algorithm, which is similar to the EKF estimator. FGO has been successfully applied to robotics applications, such as visual or light detection and ranging (LiDAR) simultaneous localization and mapping (SLAM), where it has shown significant improvement over traditional approaches. Recently, a team from Tsinghua University has been working on GNSS-INS-FGO integration and has demonstrated a significant reduction in 2D mean error of 9.14 m with a standard deviation of 6.41 m, when tested in an urban canyon.
Moreover, this method can significantly reduce the amount of time it takes for the EKF to compute the state estimate by utilizing a more sophisticated filtering scheme. It can also handle high output rates for a continuous update of the navigation solution, which is particularly important for vehicles that must operate at high speeds in dynamic environments. This is a major advantage of FGO, which can achieve the desired performance with fewer iterations than the EKF and also minimizes the computational burden by using a smaller window size in the FGO algorithm.
0users like this.
- Home
-
All Products
Your cart is currently empty.