
INT
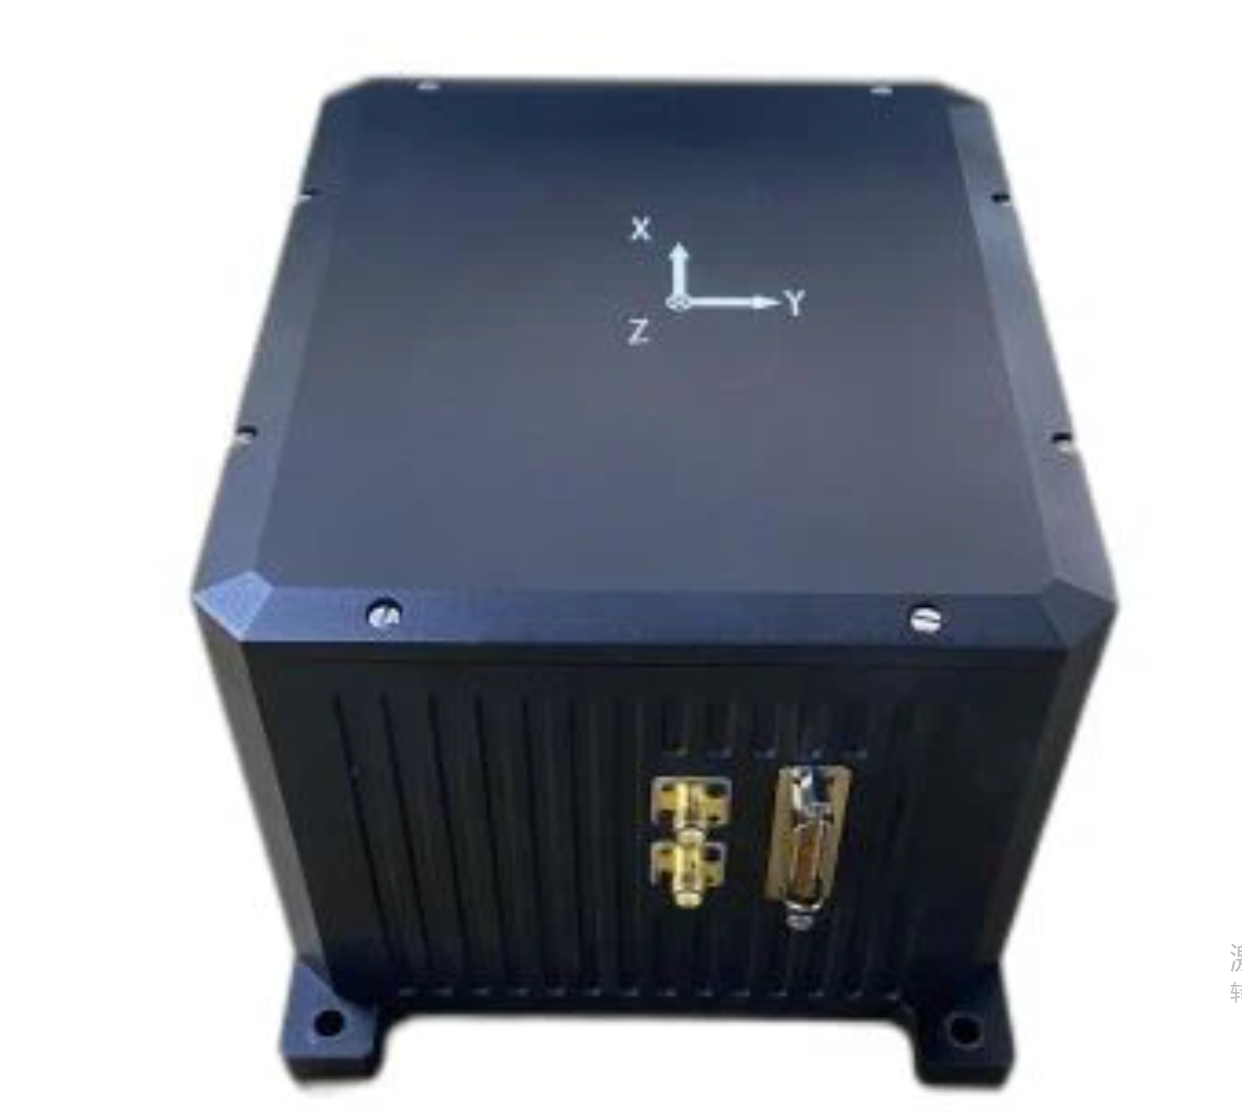

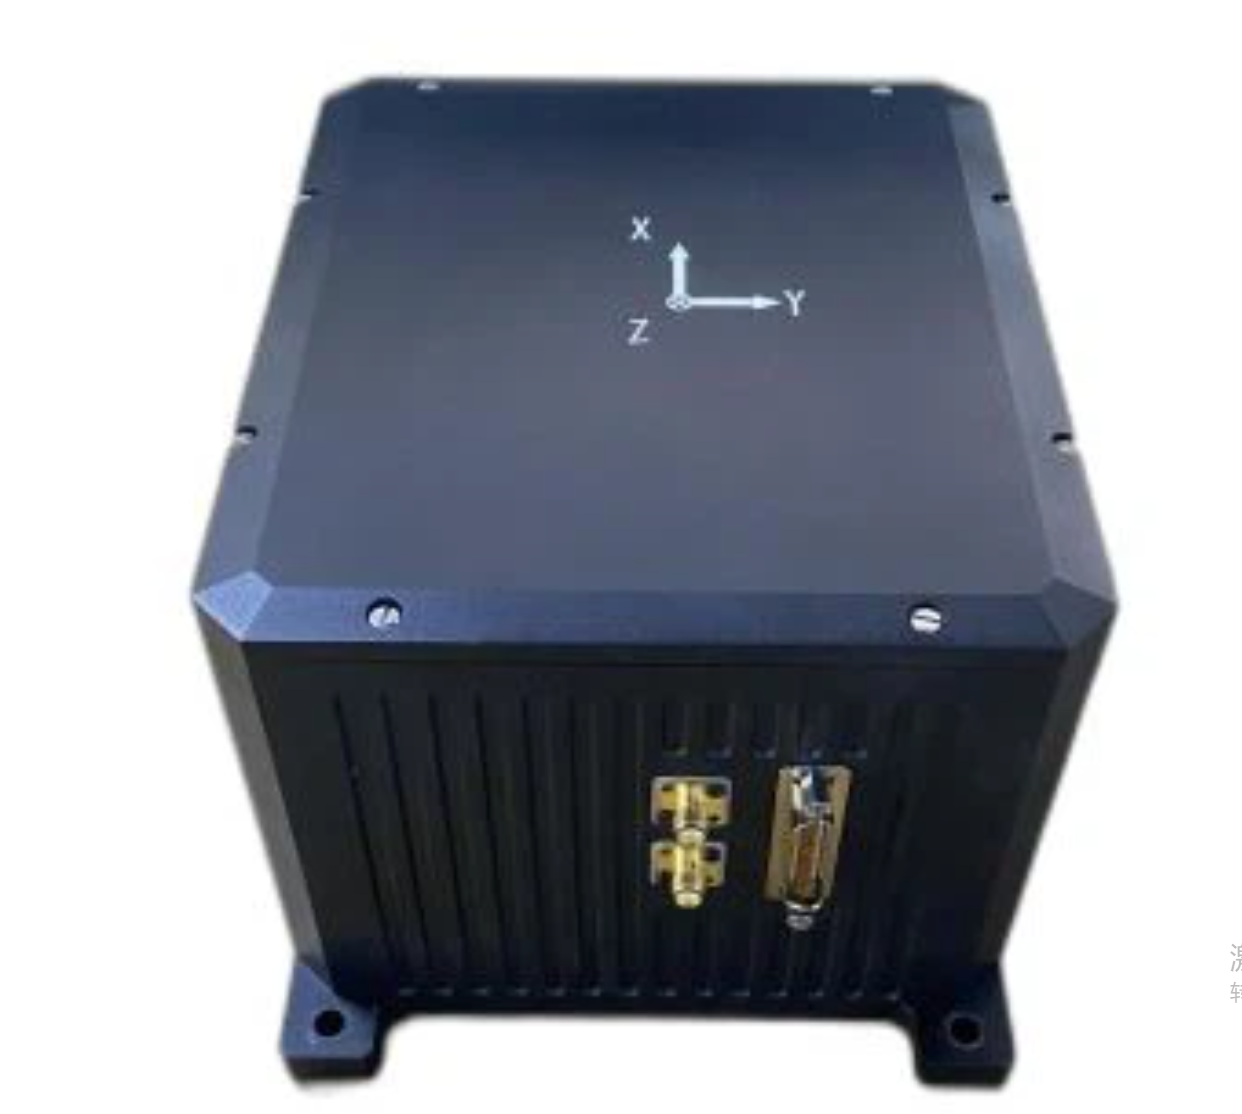
INT-400 FOG Integrated Navigation System Strapdown Inertial/Satellite INS
Introduction
The FSI400 Fiber Optic Strapdown Inertial/Satellite Integrated Navigation System is a highly reliable and cost-effective navigation system that can be widely used in navigation, control, and measurement applications represented by aircraft, unmanned ground vehicles, unmanned surface vessels, and unmanned aerial vehicles.
The integrated navigation system inherits the modular design concept of similar products, employing high-precision closed-loop fiber optic gyroscopes (FOGs) and high-accuracy accelerometers, combined with a high-performance GNSS module. The hardware circuitry adopts an FPGA+DSP architecture.
Through multi-sensor fusion algorithm processing, the GPS-derived position and velocity are fed into the filter, while the INS-derived position, velocity, and attitude also serve as filter inputs. The filter compares the discrepancies between the two to establish an error model for estimating INS errors. These errors are then used to correct the inertial navigation results, yielding integrated navigation solutions for velocity, position, and attitude.
The inertial navigation system supports different configuration modes to adapt to various platforms, such as airborne, vehicle-mounted, and shipborne applications. For land vehicle applications, vehicle motion constraints are incorporated. Through error estimation and correction, the system achieves long-duration, high-precision navigation and positioning capabilities for the host platform.
The product offers various configuration modes to adapt to different carriers, such as airborne, vehicle-mounted, and shipborne applications. For vehicle-mounted use, it incorporates vehicle constraints to ensure long-term attitude measurement accuracy.
Table 1 Performance parameters of INT-400 combined navigation system
Fiber Optic Gyroscope | |
Measurement Range(°/s) | ±300 |
Bias(°/h) | 0.01 |
Bias Stability(°/h,10s) | 0.01 |
Bias Instability(°/h,allan) | 0.001 |
Bias Repeatability(°/h,6 power cycles) | 0.01 |
Angular Random Walk(°/√h) | 0.0005 |
Scale Factor Nonlinearity(ppm) | 10 |
Scale Factor Asymmetry(ppm) | 10 |
Scale Factor Repeatability(ppm) | 10 |
Cross-Coupling(rad) | ≤0.001 |
Bandwidth(Hz) | ≥200 |
Quartz Accelerometer | |
Measurement Range( g) | ±20 |
Zero Offset(mg,1σ) | ≤ 0.1 |
Bias Stability(ug,10s smoothing) | 10 |
Bias Instability(ug,allan) | 5 |
Bias Repeatability(ug) | 10 |
Velocity Random Walk(mm/s/√h) | 5 |
Scale Factor Nonlinearity(mg,ppm) | 5 |
Cross-Coupling(rad) | 10 |
Bandwidth(Hz) | ≥200 |
Inertial Navigation Accuracy | |
Self North Finding Accuracy(°,1σ) | 0.06 |
Attitude Alignment Accuracy(°,1σ) | 0.005 |
Yaw Maintaining(°/h,1σ) | 0.06 |
Attitude Maintaining(°/h,1σ) | 0.03 |
Horizontal Speed(m/s,1σ) | <0.3 |
Inertial Navigation Accuracy(1σ) | <1n mile/h |
Depth Measurement Accuracy(cm) | 5 |
Inertial/odometer combination accuracy | ≤0.002D |
Combined Navigation Accuracy | |
Combined heading (°, 1σ, real-time) | 0.03 |
Combined horizontal attitude (°, 1σ, real-time) | 0.01 |
Combined heading accuracy (°, post-processing) | 0.003 |
Combined horizontal attitude (°, post-processing) | 0.001 |
Combined horizontal position (m, 1σ) | 3(single point)),0.02+1ppm(RTK) |
Combined celestial position (m, 1σ) | 5(single point)),0.03+1ppm(RTK) |
Combined horizontal velocity (m/s, 1σ) | 0.1 |
Combined celestial velocity (m/s, 1σ) | 0.15 |
GNSS Receiver | |
Timing Accuracy | 20ns |
Positioning time | ≤40s |
Startup time | ≤2s |
Positioning Data Update Rate | 10Hz |
Working Altitude | 10000m |
Satellite mode | GPS:L1/L2/L5; BeiDou:B1/B2/B3; GLONASS:L1/L2. |
Electrical/mechanical interface | |
Power supply | 12~36VDC(建议24V) |
Power Consumption | ≤18W |
Dimensions | 212 × 155 × 125 mm |
Weight | ≤5kg |
Usage Environment | |
Operating temperature | -40°C ~ +70°C |
Storage temperature | -55°C ~ +85°C |
Vibration | 6 g @ 20~2000 Hz |
Shock | 100 g, 11 ms |
Reliability | |
MTBF/MTTR | 10000 h / 0.5 h |
Maintenance | BIT 95% |
Fig. 1 Dimensions of the external structure


Fig. 2 Dimensions of the receiver antenna


xxxxxx
- Home
-
All Products

Your cart is currently empty.